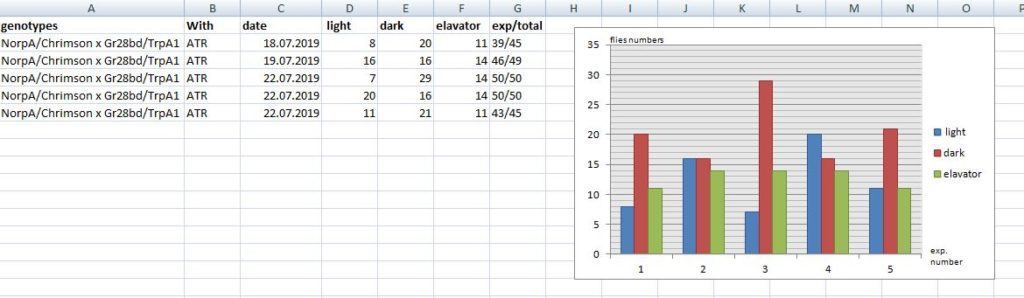
t- mase experiments results of first five experiments
on Monday, July 22nd, 2019 11:10 | by kader semiz

Category: Uncategorized | No Comments
Optimizing optomotor response, part 2
on Friday, May 10th, 2019 4:20 | by Anders Eriksson
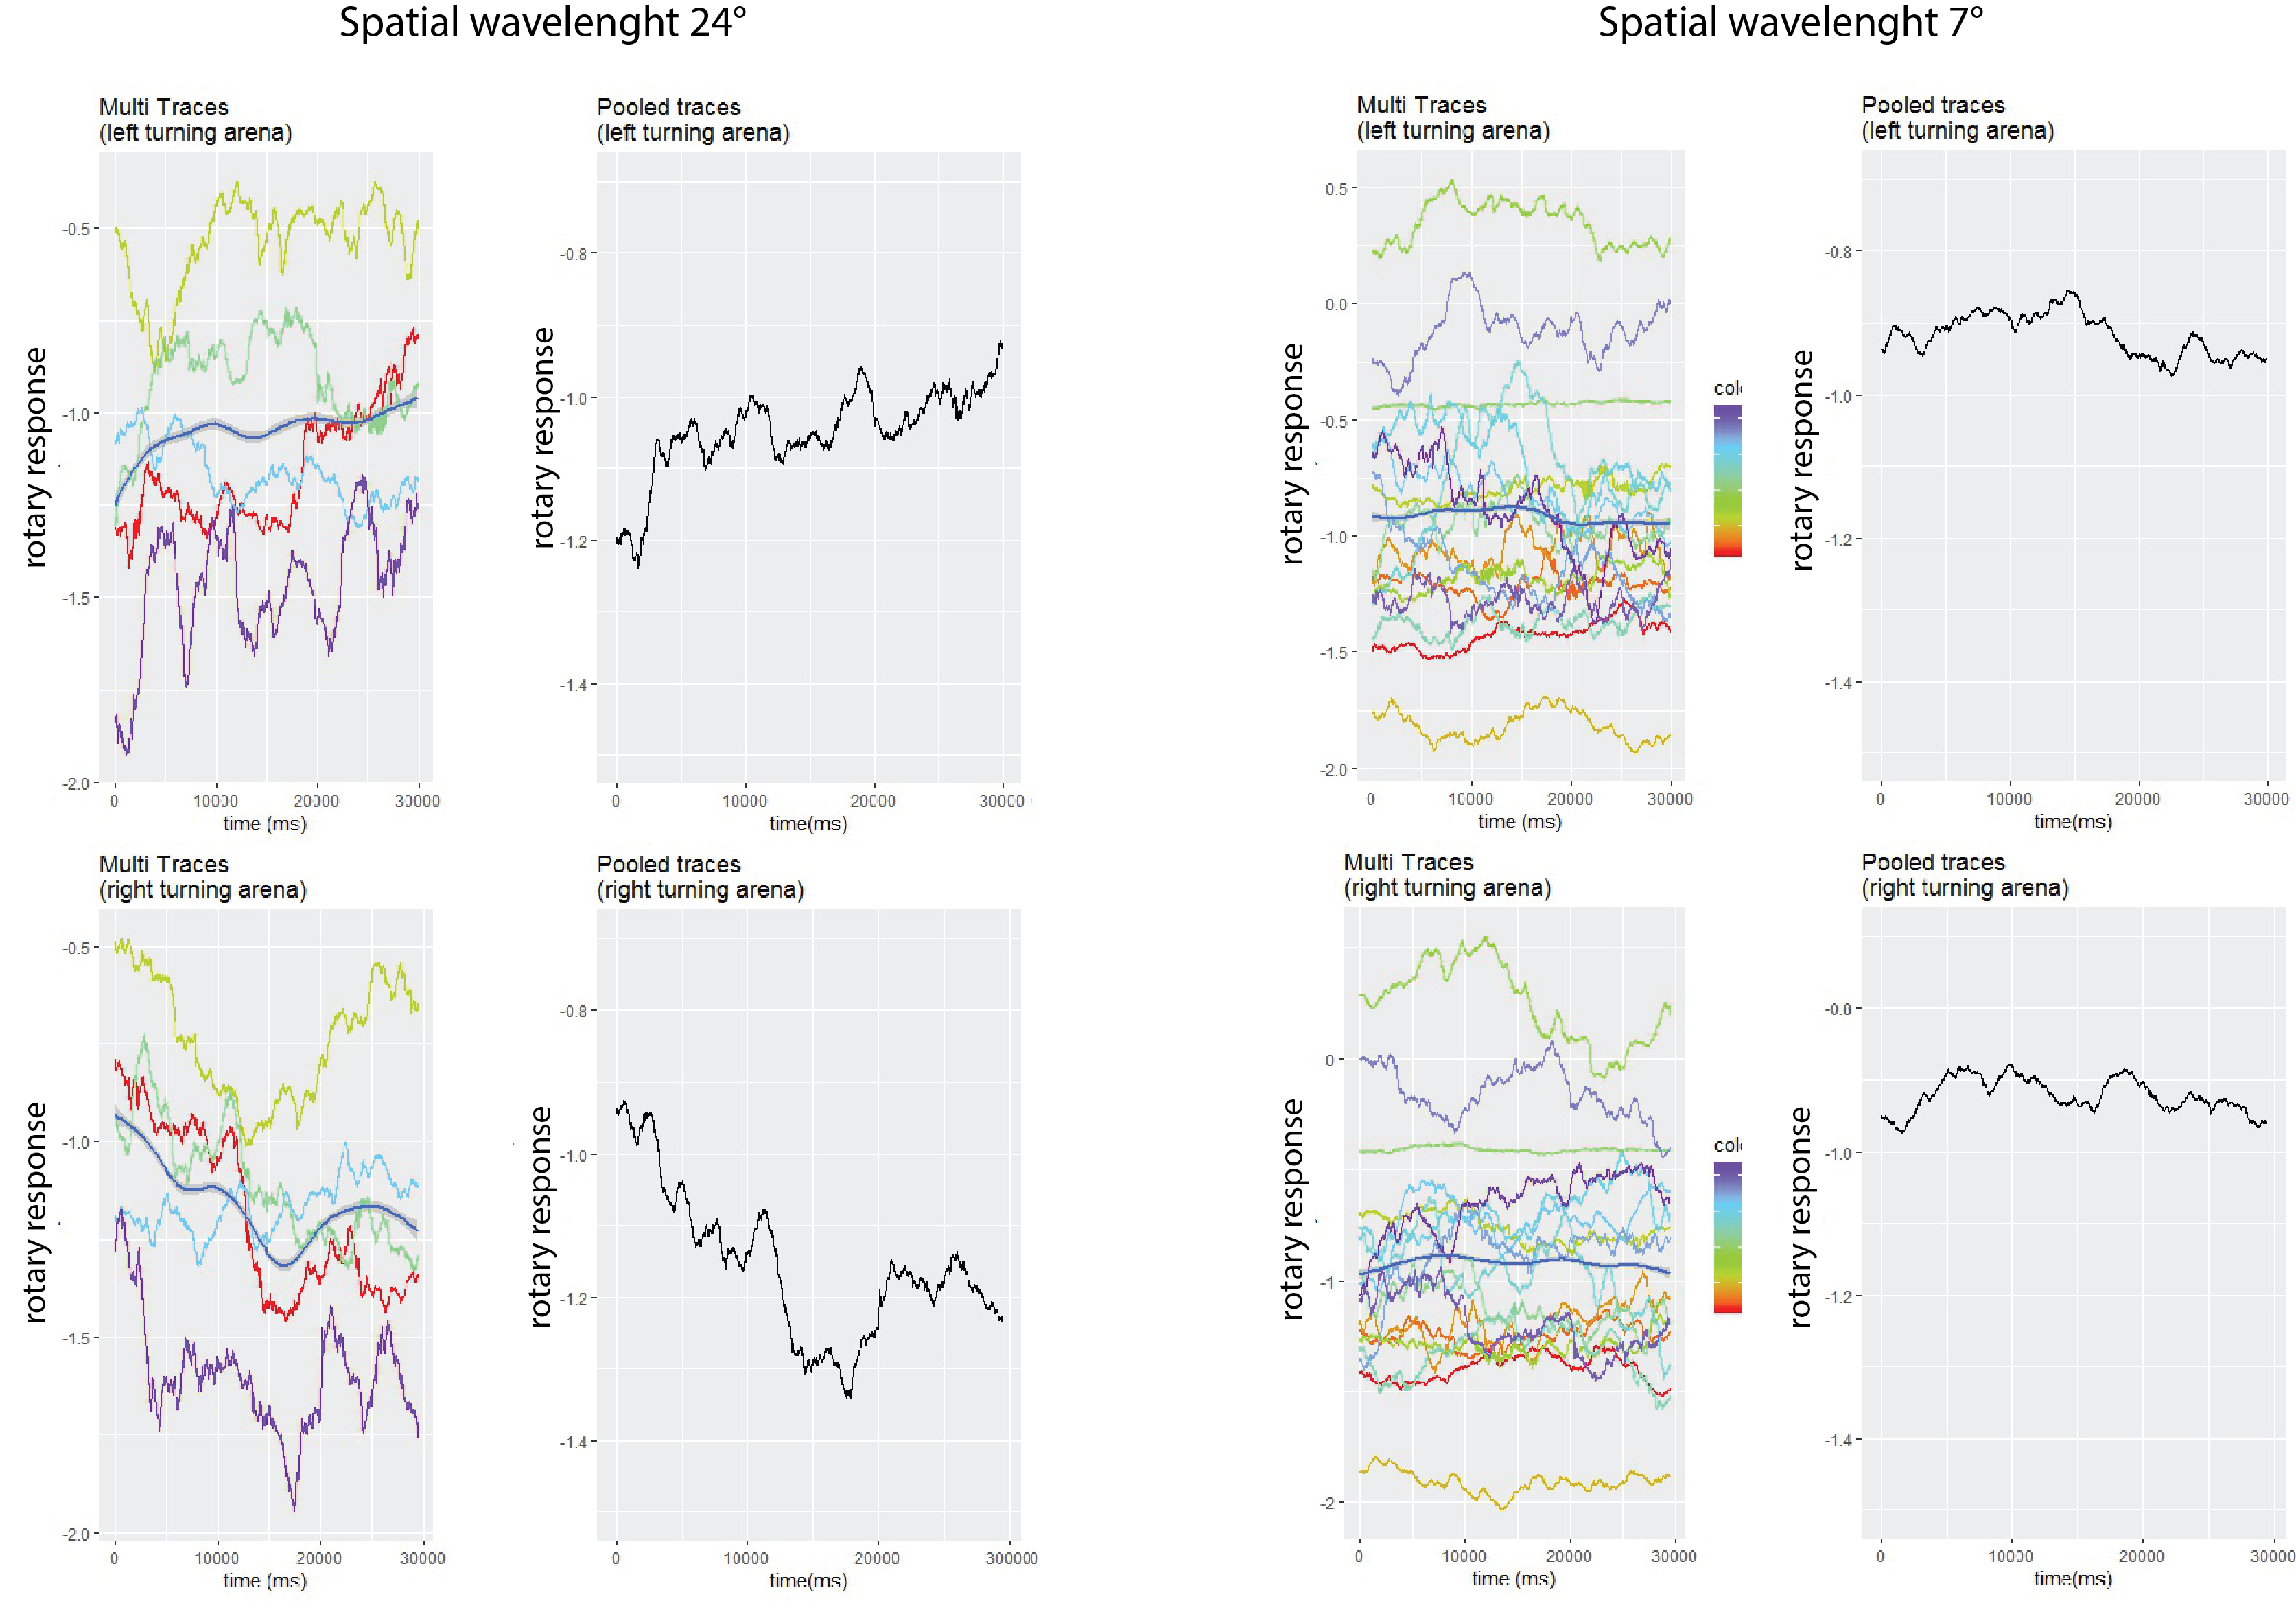
The optomotor stimulus consists of a striped arena with panoramic vertical stripes rotating horizontally around the vertical, or yaw axis. Depending on the spatial wavelenght (or spatial frequency, SF) the fly’s optomotor response (OR) is changing supposedly to reach a maximum between 20-40°
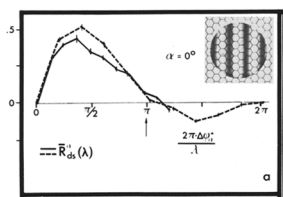
(with a pattern motion of 0° ) . As the panoramic stripes are rotating a tethered fly will actively steer in the direction of the motion. After its maximum the OR gradually decreases with an increasing spatial frequency to finally reach 0 around 9.6-6.3°. A tendency to negative/reversed OR has been observed as the SF reaches 6.3°.
This experiment has been shown before in 1976 by E. Buchner, Elementary movement detectors in an insect visual system. Bioi Cybern 24:85- 101, Figure 8 page 93. Attaching Figure 8 as a reference.
Category: Uncategorized | No Comments
Optimizing optomotor response
on Tuesday, May 7th, 2019 4:56 | by Anders Eriksson
Category: Uncategorized | No Comments
Habit formation, Registered Report
on Monday, April 1st, 2019 2:16 | by Anders Eriksson
Started to write the manuscript for the registered report about Habit formation. Aiming for European Journal of Neuroscience.


Category: Uncategorized | No Comments
Software stops measuring at the correct sample rate
on Monday, March 25th, 2019 2:59 | by Anders Eriksson

Category: Uncategorized | No Comments
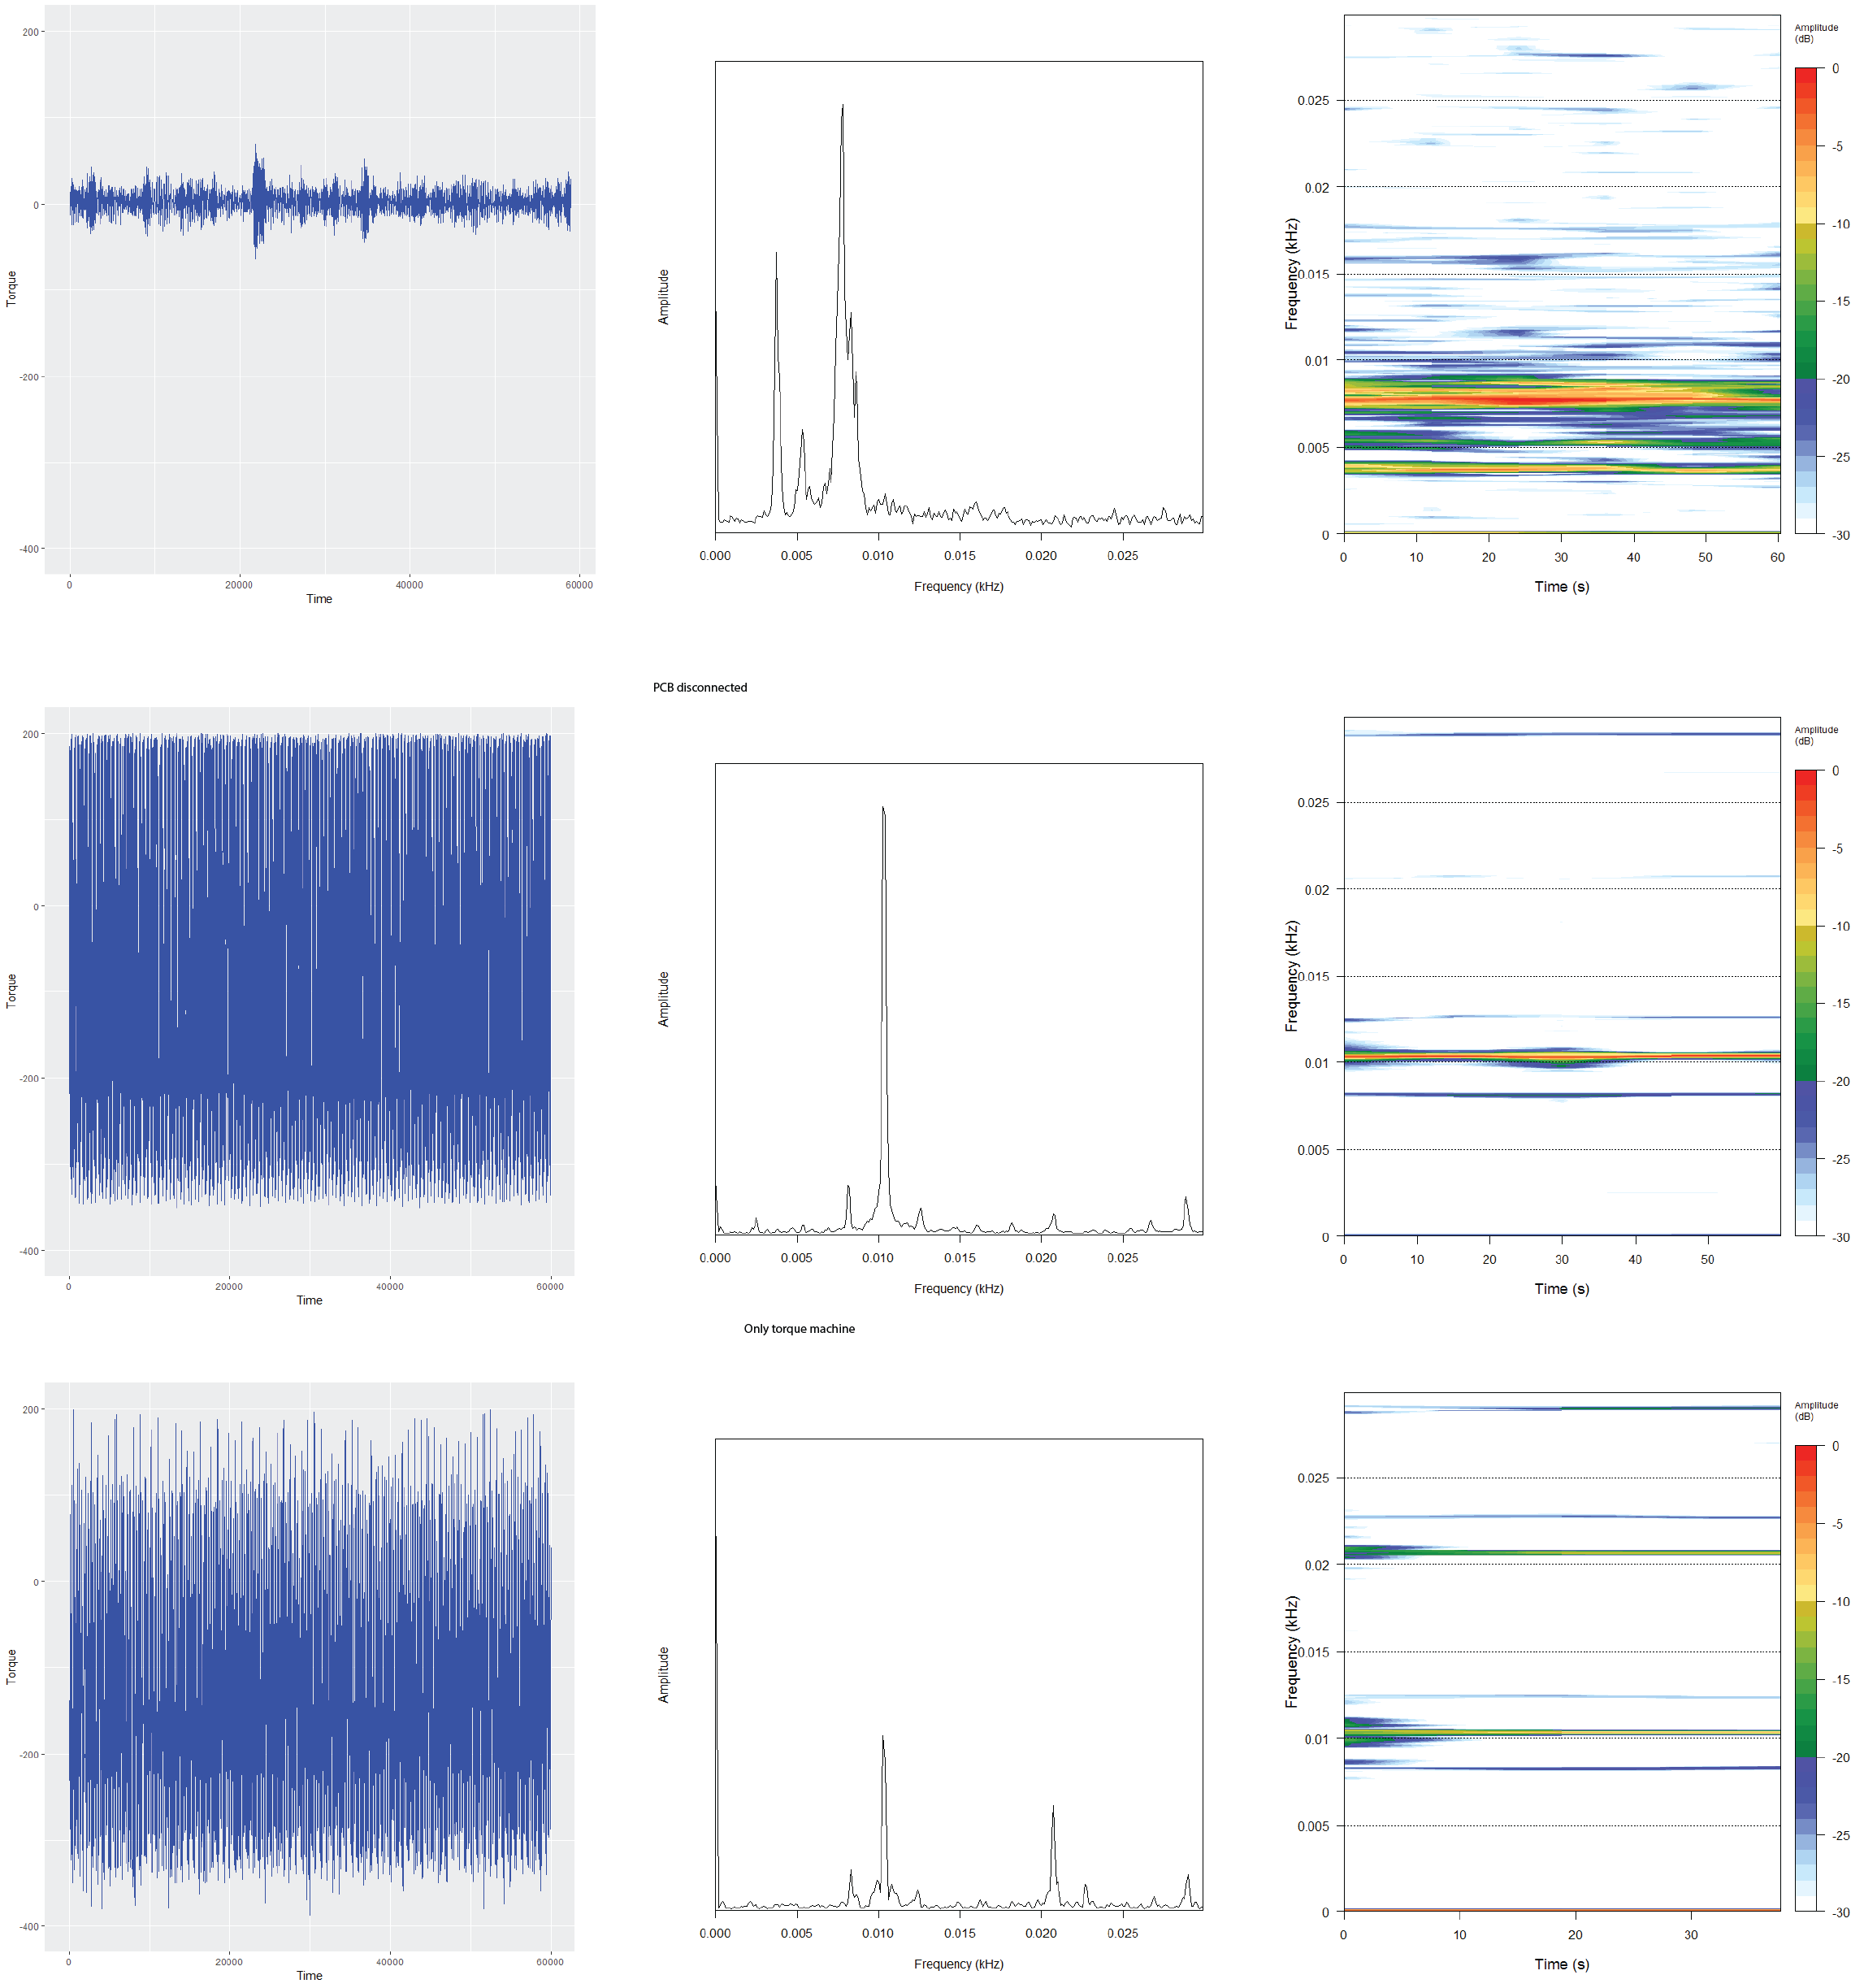
Noise measurements
on Wednesday, March 20th, 2019 9:06 | by Anders Eriksson
Three different kind of noises has been measured: Without input from the torquemeter, without input from the PCB and one also with everything connected but the power supply turned off.
Category: Uncategorized | No Comments
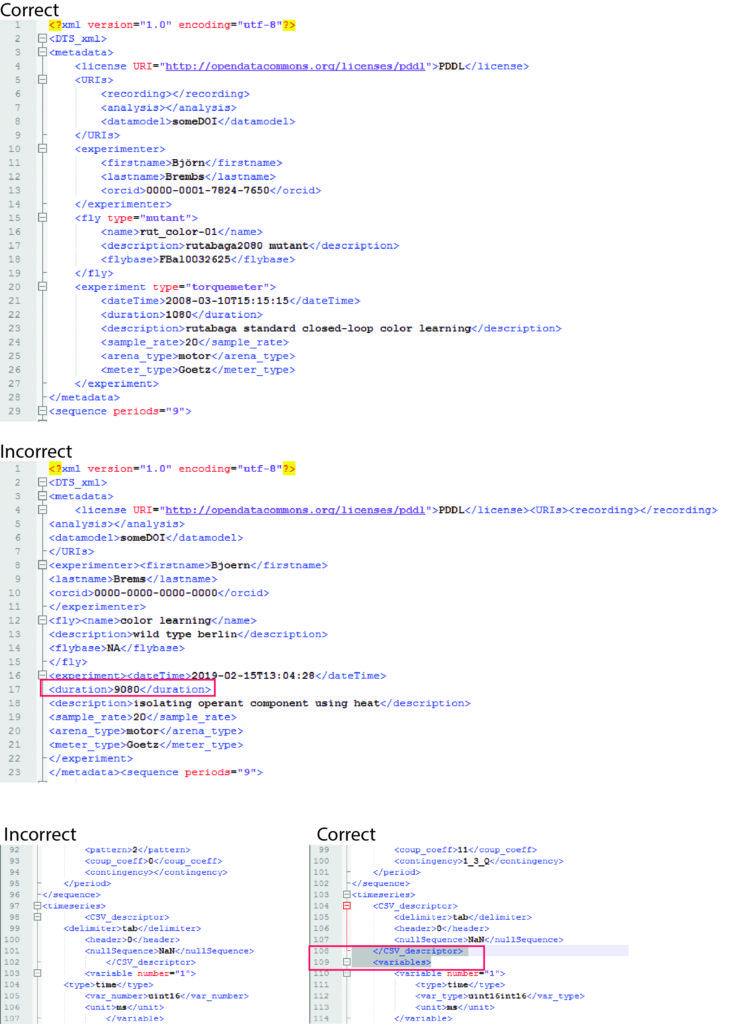
Finding errors in the new software
on Monday, February 18th, 2019 3:00 | by Anders Eriksson
Category: Uncategorized | No Comments
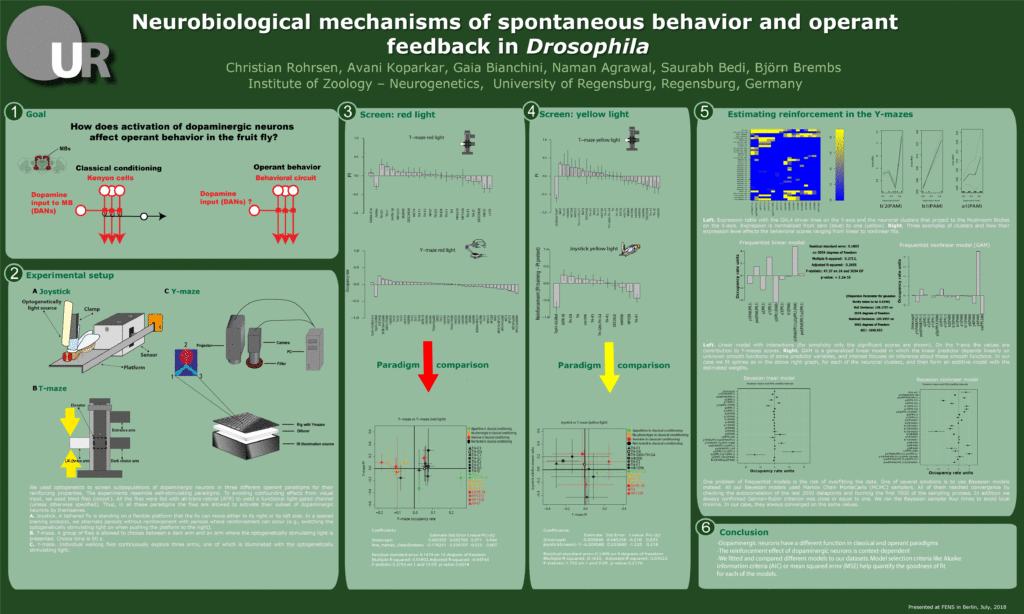
FENS poster (link for students)
on Thursday, February 14th, 2019 11:21 | by Christian Rohrsen
Category: Uncategorized | No Comments
Implementing color learning on projector
on Monday, February 11th, 2019 3:02 | by Anders Eriksson
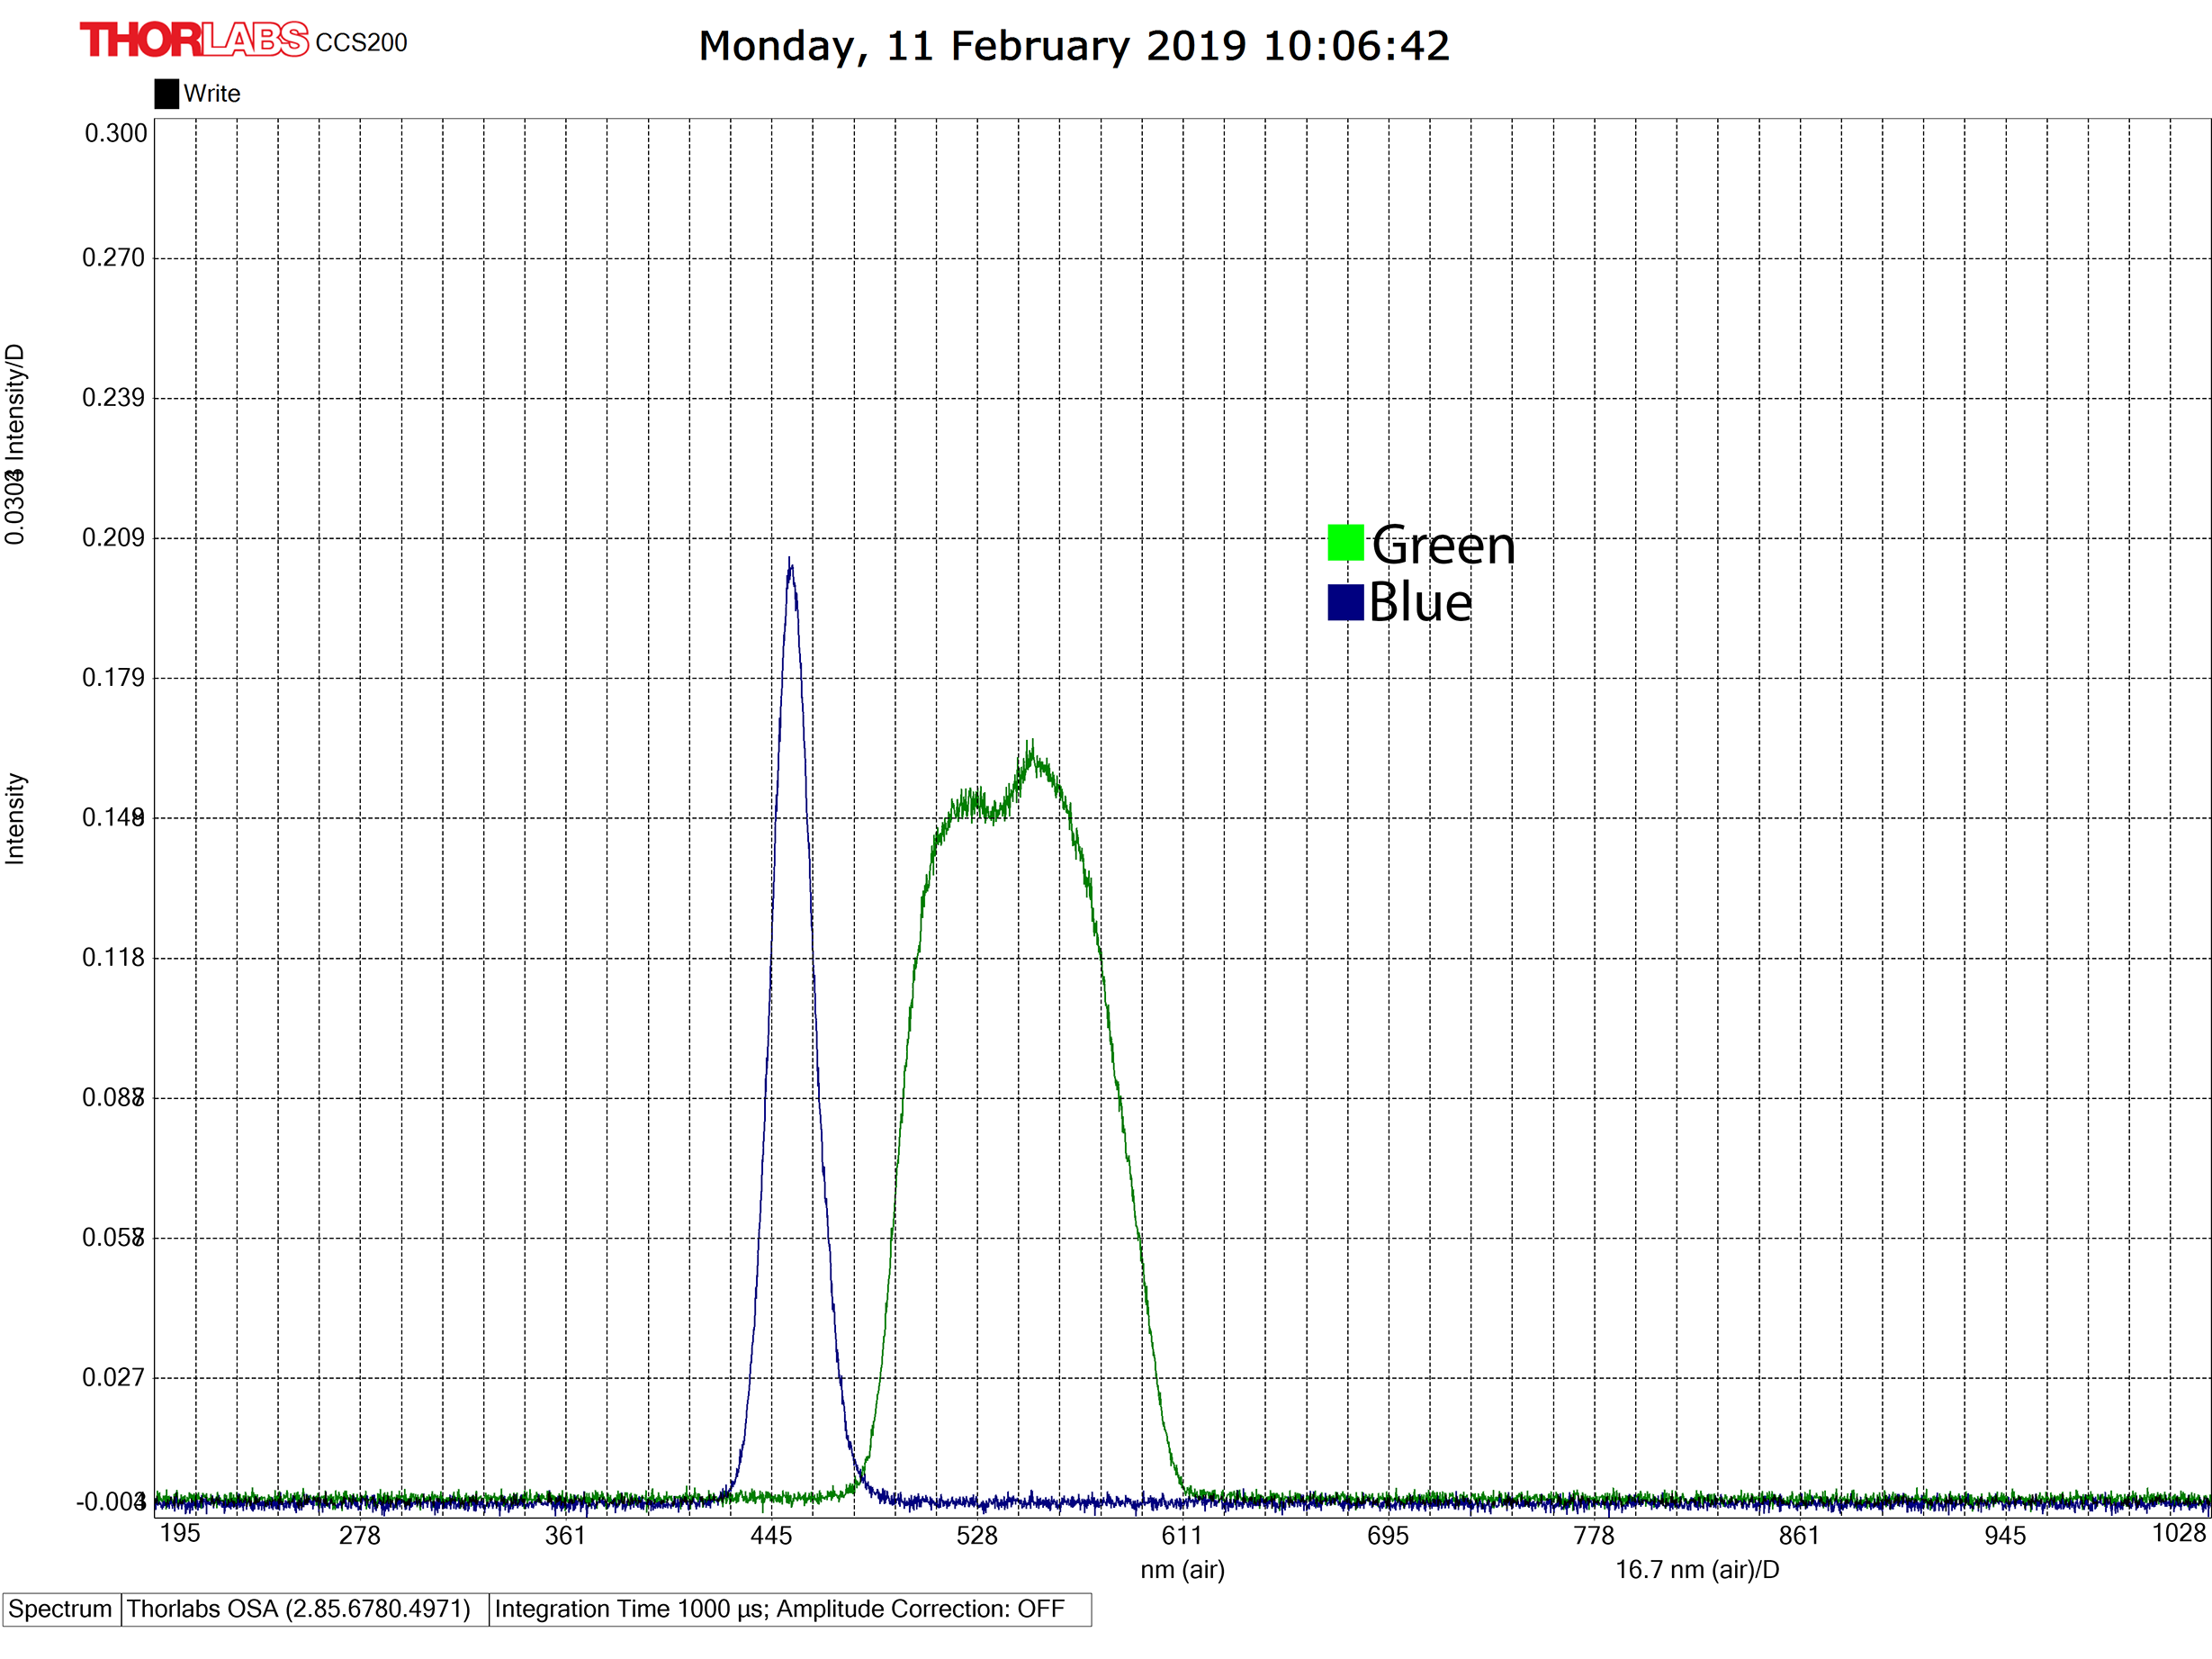
Colors have been implemented in the projector. It has been difficult to evaluate due to some bugs in the code:
- The program remembers the most recent color and is not returning to a white background when switching between different colors.
- Only striped pattern seems to be implemented?
These issues have been addressed Johann Schmid and he will update the program accordingly.
The color learning is working as it should. It is changing the color accordingly to the set pattern. Laser is also implemented correctly
Category: Uncategorized | No Comments
Isolated operant component in the flight simulator
on Monday, January 21st, 2019 2:43 | by Anders Eriksson
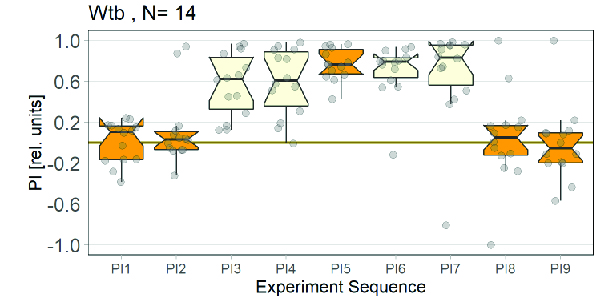
Each period is set to 120 seconds, meaning that the flies are getting a total of 8 minutes of training. The flies are performing two initial pre-tests, one test after 4 minutes of training and two final test periods. For the entire duration of the experiments flies are given a color indication if they are being punished or not as a result of left or right turning, this is a composite learning control. For the final test periods the colors have been removed, meaning that we are isolating the operant component. This is different from the previous tests that has been done where flies were not challenged with colors but just relied on their own behavior to determine which side is being punished. A removal of the helping colors resulted in a lack of preference for left- or right-turning maneuvers.
Category: flight, Memory, Operant learning, operant self-learning, Uncategorized | No Comments